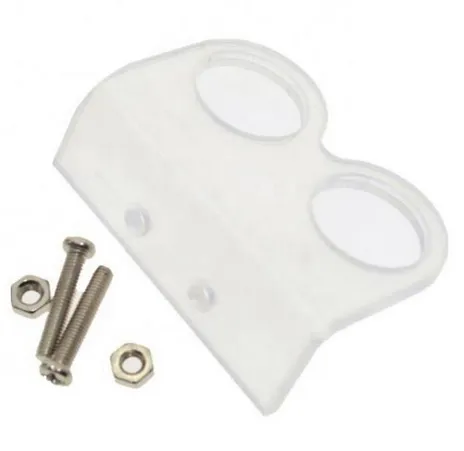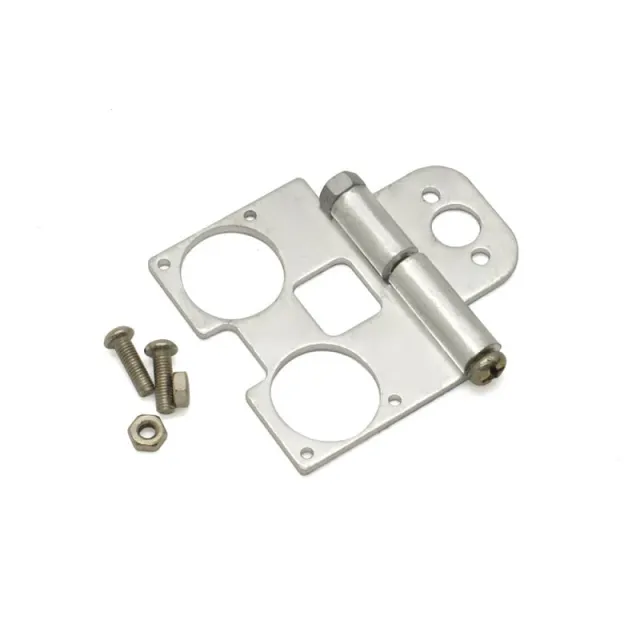
SKU: OT3624 Article number: NB009 EAN: 8720618827135
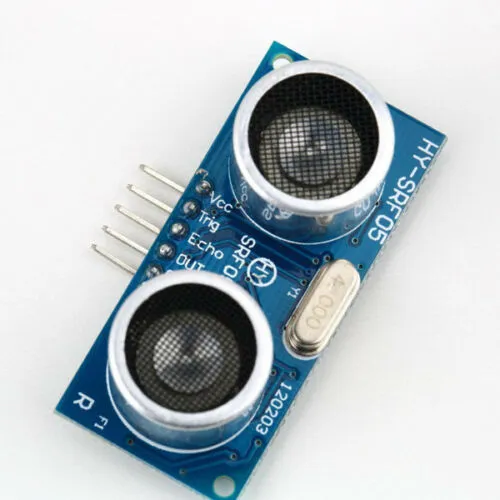
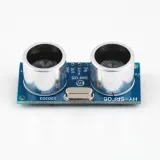
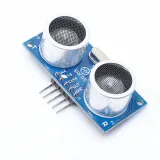
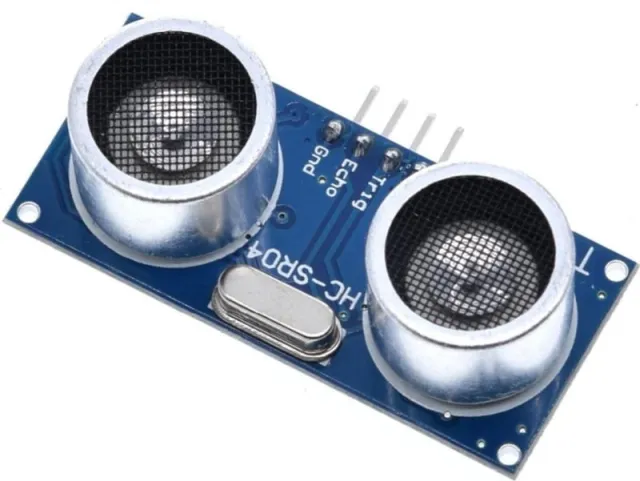
The HY-SRF05 Ultrasonic Range Finder module uses ultrasonic sound waves to detect the presence and measure the distance to objects in front of it.
MAIN FEATURES:
2cm - 450cm (15 feet) detection range
40 kHz operation
±15 degrees field of view
5V operation
The detection and measurement range is from 2 cm to 450 cm with a specified accuracy of ± 2 mm. The ultrasonic sound pulses at 40 kHz and is not audible to the human ear. The HY-SRF05 is a higher precision version than the HC-SR04, but is otherwise similar in functionality.
These modules are often used on robotic vehicles for detecting and avoiding obstacles. Because they use sound waves for detection, they are not sensitive to light sources or optically reflective surfaces as IR can be. By using sound instead of light, it is also possible to measure the time it takes for the sound to echo back, and therefore the distance to the object can be calculated with a fair amount of accuracy, which can be quite handy.
The modules have a 'view' of about ±15 degrees, which is why they are sometimes mounted on a servo motor so the sensor can 'look' at its surroundings. The fact that the sensors look like a pair of eyes also adds to the cool factor.
The module is normally inactive.
A 10uSec or wider logic HIGH pulse is sent to the TRIG pin on the module, usually by a microcontroller. This causes the module to start a detection cycle.
The module emits eight bursts of 40KHz sound and sets its ECHO pin output HIGH.
When the signal is reflected by an object and detected by the module, the ECHO pin is set LOW again.
By measuring how long the ECHO pin is held HIGH, the distance to the object can be calculated using the basic formula (Time ECHO is held HIGH * Speed of Sound / 2). Dividing by 2 is because the sound has to travel both ways (to and from the object) and we only want to know the one-way distance.
If no echo returns (no object detected or signal is blocked), the module will still pull the ECHO pin low after a fixed delay. This delay can vary, but is about 200 mSec on the modules I have measured. This is necessary to prevent the module from hanging if there is no echo.
The speed of sound varies a bit with air temperature, so for maximum accuracy the air temperature can be measured and used to calculate the current speed of sound, but this is not required for basic collision detection purposes.
Module connections:
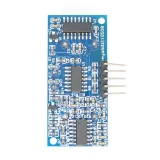
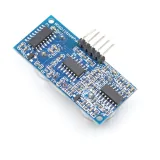
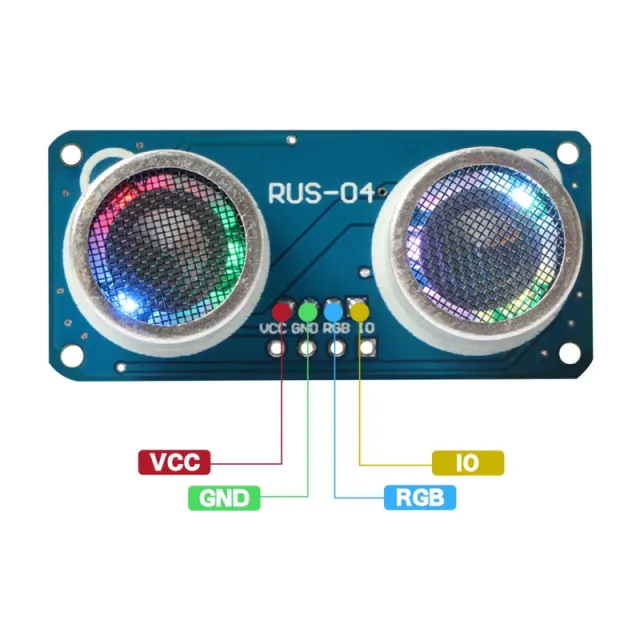
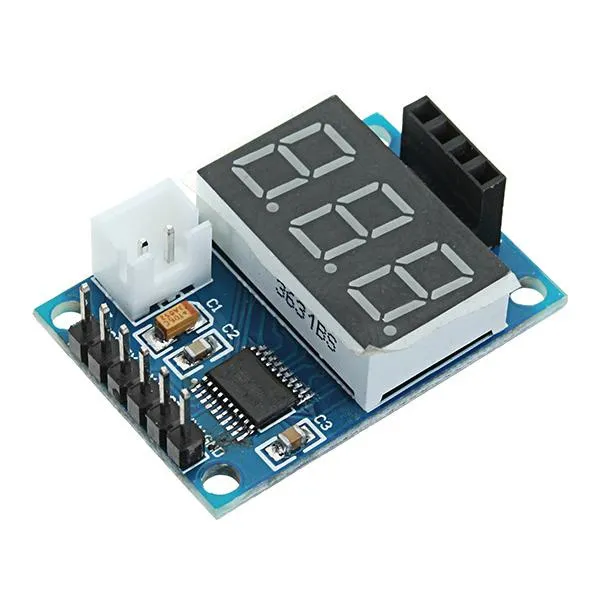
There is a 5-pin header on the assembly. The GND pin is connected to system ground and the Vcc pin is connected to 5V. The TRIG pin is an input pin to which a 10uSec pulse is applied to start the measurement cycle. The ECHO pin is an output pin that is held HIGH for the time from when the module emits a 40KHz pulse until it receives the echo back. The OUT pin is not used.
1 x 5 header
VCC – Connect to 5V.
TRIG – Trigger Input – Connect to a digital output pin on MCU. A pulse of 10 uSec or wider starts a measurement cycle.
ECHO - Echo Output - Connect to a digital input pin on MCU. This pin is held high during the measurement cycle.
OUT – Not used
GND – Connect to system ground. This ground must be common with the MCU.